I’m a fourth-year Ph.D. candidate in the Department of Civil and Environmental Engineering, National University of Singapore, advised by Prof. Kaidi Yang.
My research lies at the intersection of intelligent transportation systems, reinforcement learning, and control theory. I develop algorithms for traffic operations and decision-making of networked agents, with applications in autonomous driving, UAV swarm prediction and control, and incident management. My latest CV is available here.
🔥 News
- 2026.05: 🎉🎉 Our paper on rollback-based LLM safety alignment was accepted by ICML 2026!
- 2025.12: 🎉🎉 Our paper on cooperative mixed-autonomy platoon control was accepted by IEEE T-ITS!
- 2025.09: 🎉🎉 Our paper on bi-level control at weaving sections was accepted by IEEE T-ITS!
- 2025.07: 🎉🎉 Our paper on interaction-aware trajectory prediction was accepted by IEEE T-ITS!
- 2025.07: 🎉🎉 Our paper on control-aware trajectory prediction for UAV swarms was accepted by ACC 2025!
- 2025.07: 🎉🎉 Our paper on safe mixed-autonomy platoon control was accepted by ACC 2025!
- 2025.03: 🎉🎉 Our paper on verification of string stability was accepted by ICLR Workshop 2025!
- 2024.03: 🎉🎉 Our paper on system-level safe platoon control was accepted by IEEE T-IV!
- 2024.01: 🎉🎉 Our paper on safe vehicle control with conformal prediction was accepted by JPCS 2024!
- 2023.09: 🎉🎉 Our paper on policy-distilled RL for freeway accident disposal was accepted by Accident Analysis & Prevention!
- 2023.03: 🎉🎉 Our paper on DRL-based platton control was accepted by ITSC 2023!
- 2023.03: 🎉🎉 Our paper on safe vehicle control with conformal prediction was accepted by JPCS 2024!
- 2023.01: 🎉🎉 Our paper on collaborative decision-making of highway emergency response was accepted by Sustainability!
📝 Publications
Highlights
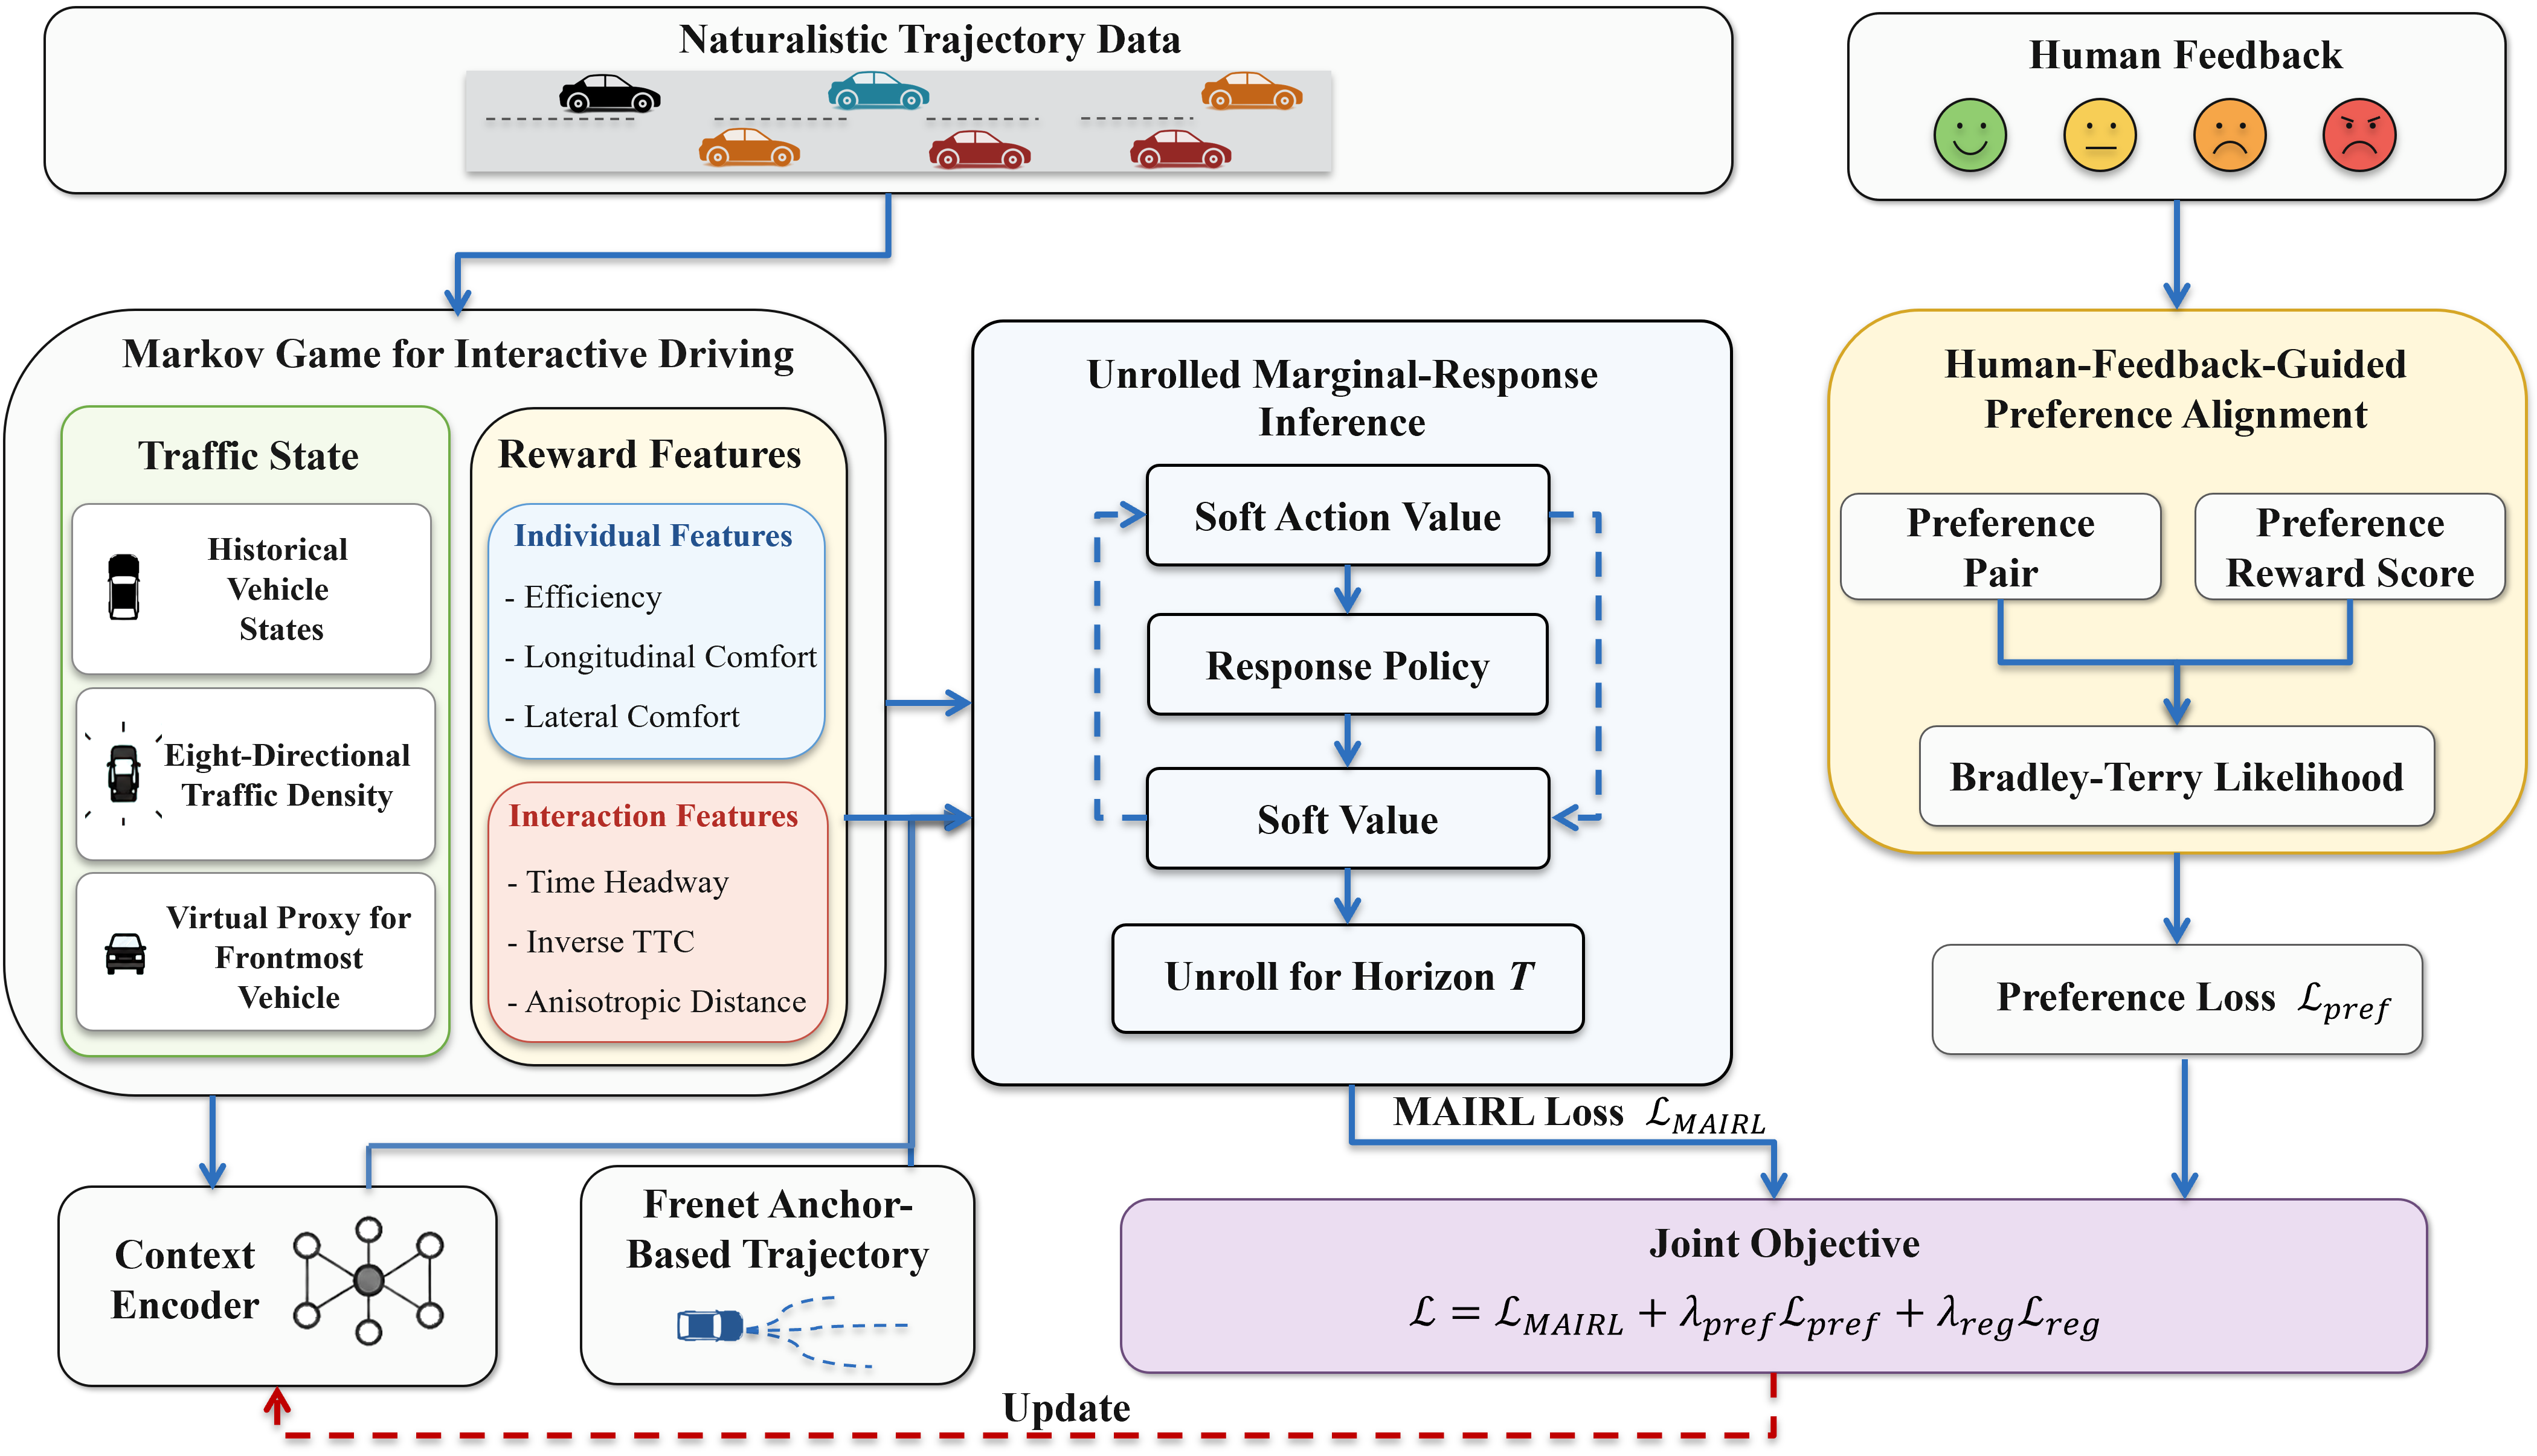
Human-Feedback-Guided Multi-Agent Inverse Reinforcement Learning for Interactive Driving Behavior Modeling
Longhao Yan, Jinhao Liang, Kaidi Yang
ArXiv, 2026
- A human-feedback-guided multi-agent inverse reinforcement learning framework combining localized Markov games, marginal-response approximations, and ordinal preference learning for interactive driving behavior modeling.
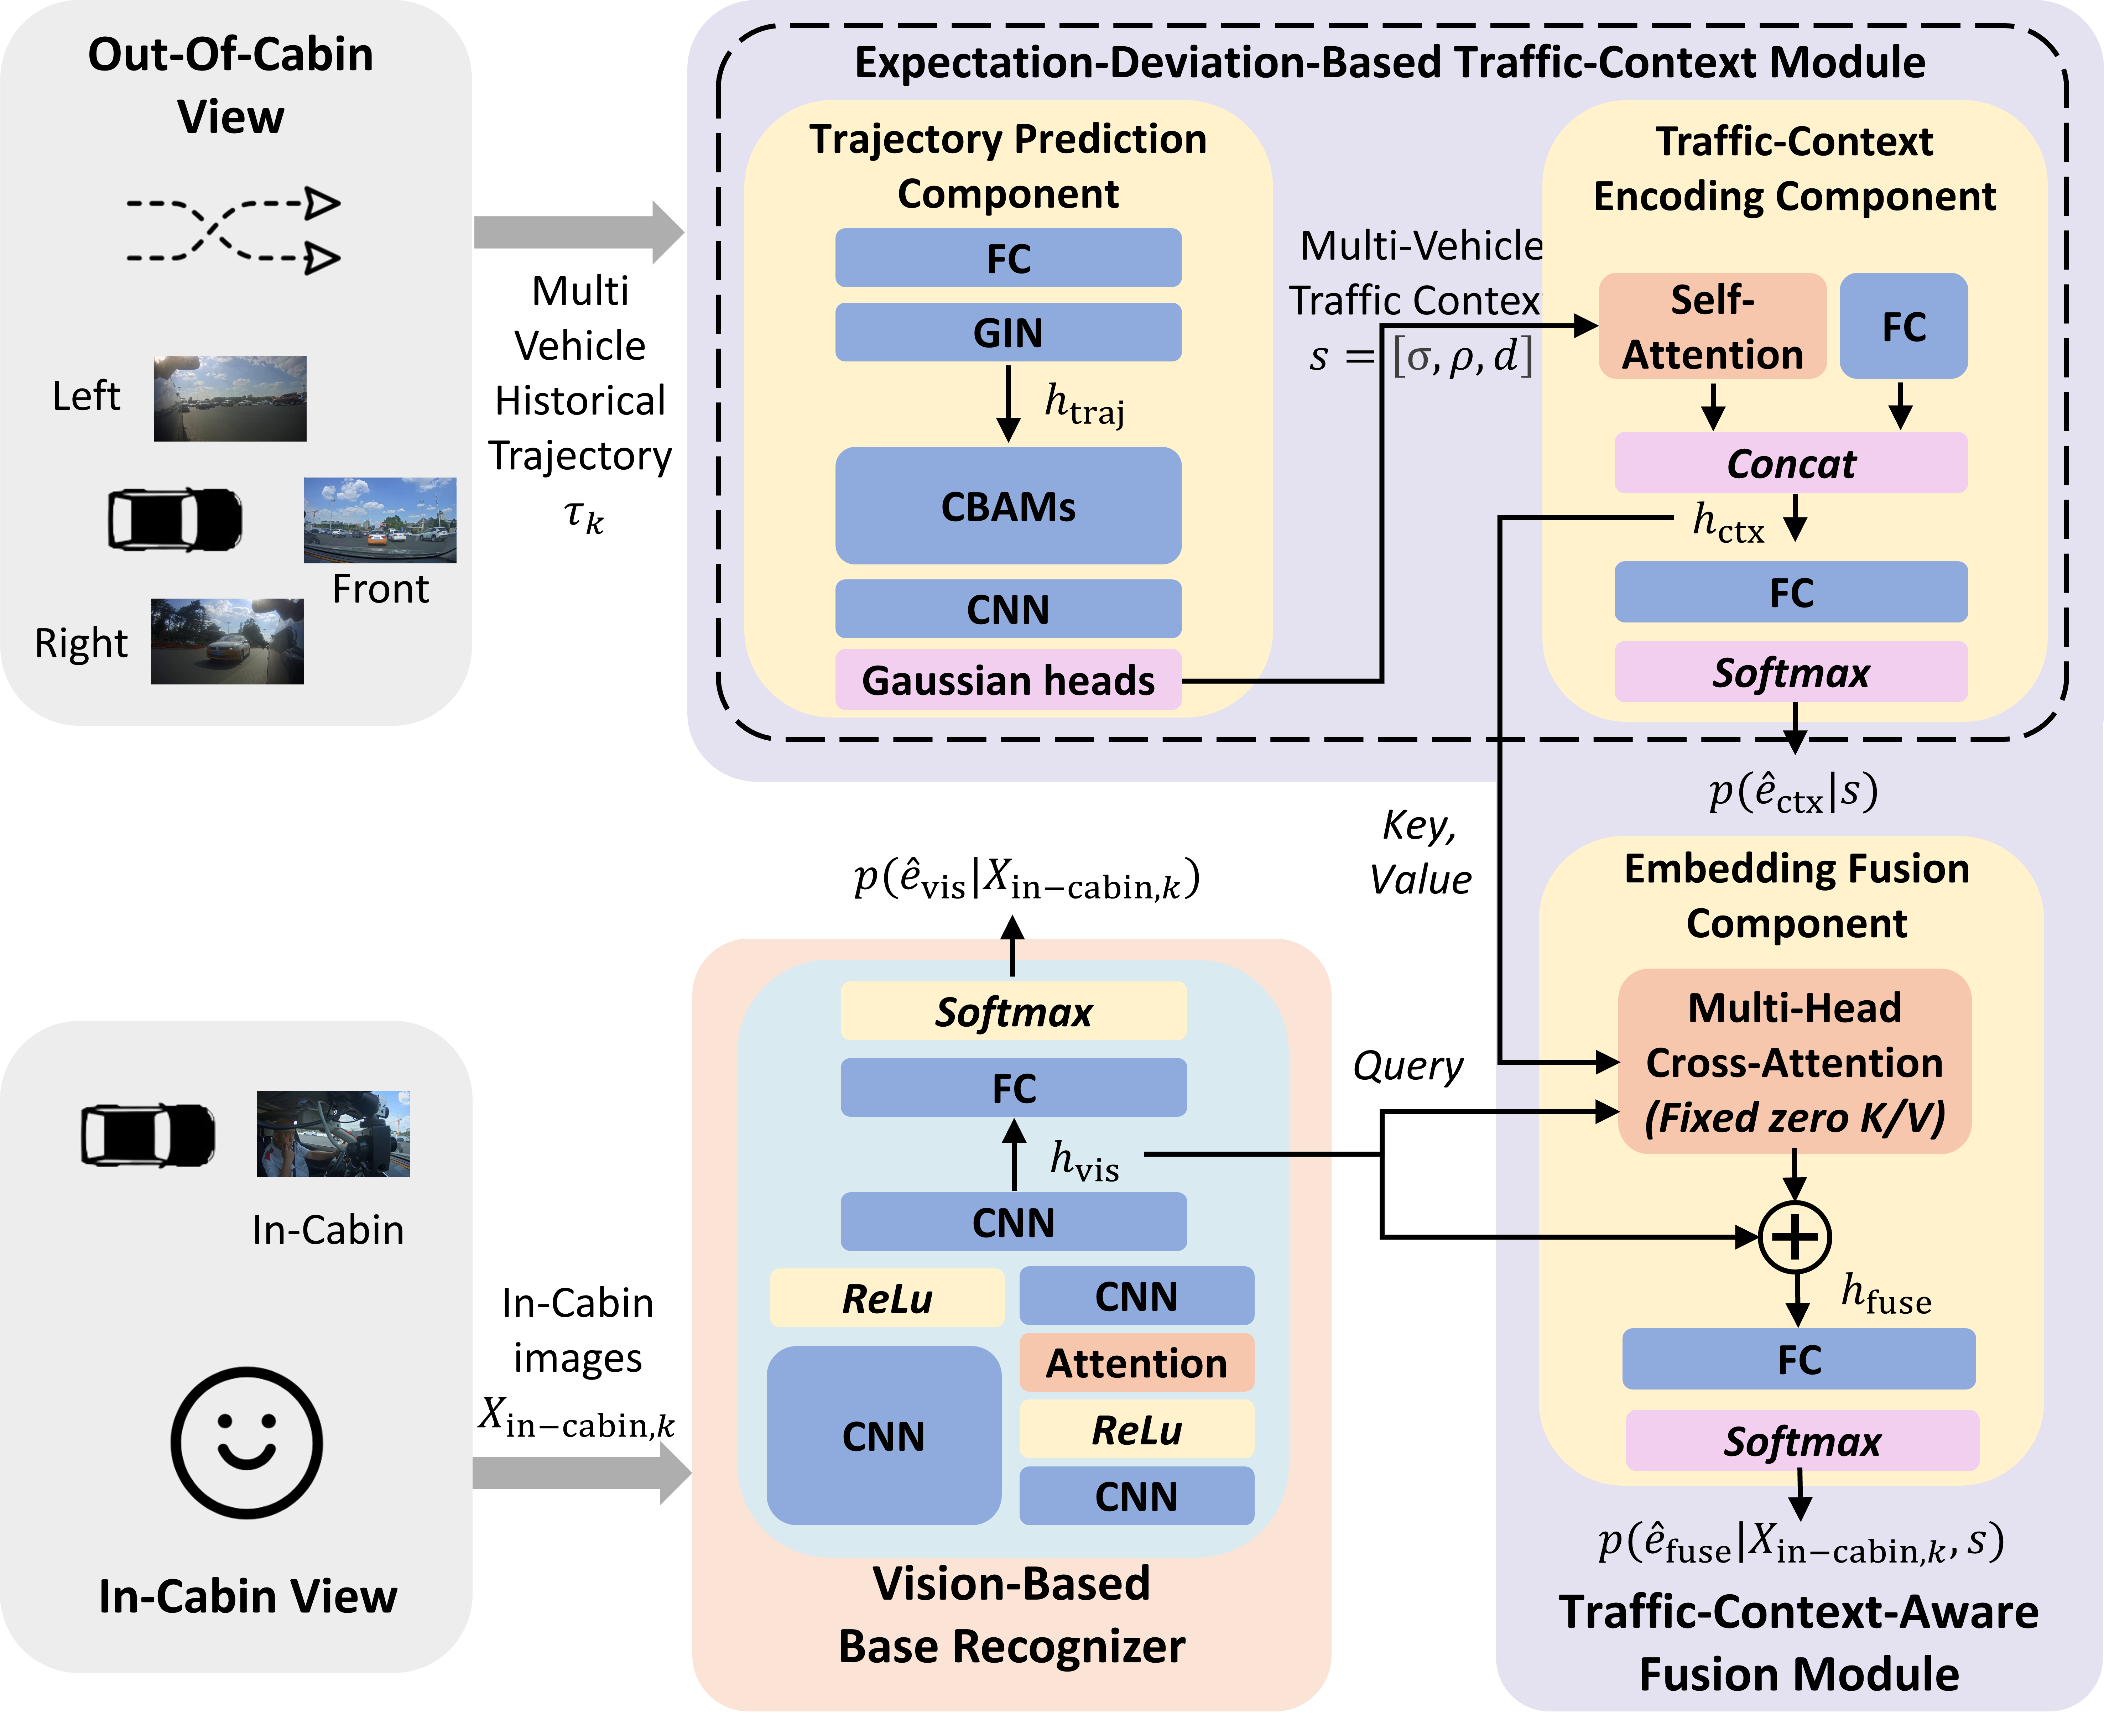
Traffic-Context-Aware Driver Emotion Recognition with Expectation-Deviation-Driven Inference
Longhao Yan, Jinhao Liang, Kaidi Yang
ArXiv, 2026
- A traffic-context-aware driver emotion recognition framework that integrates facial features with trajectory-based expectation deviations to improve emotion recognition in interactive driving scenarios.
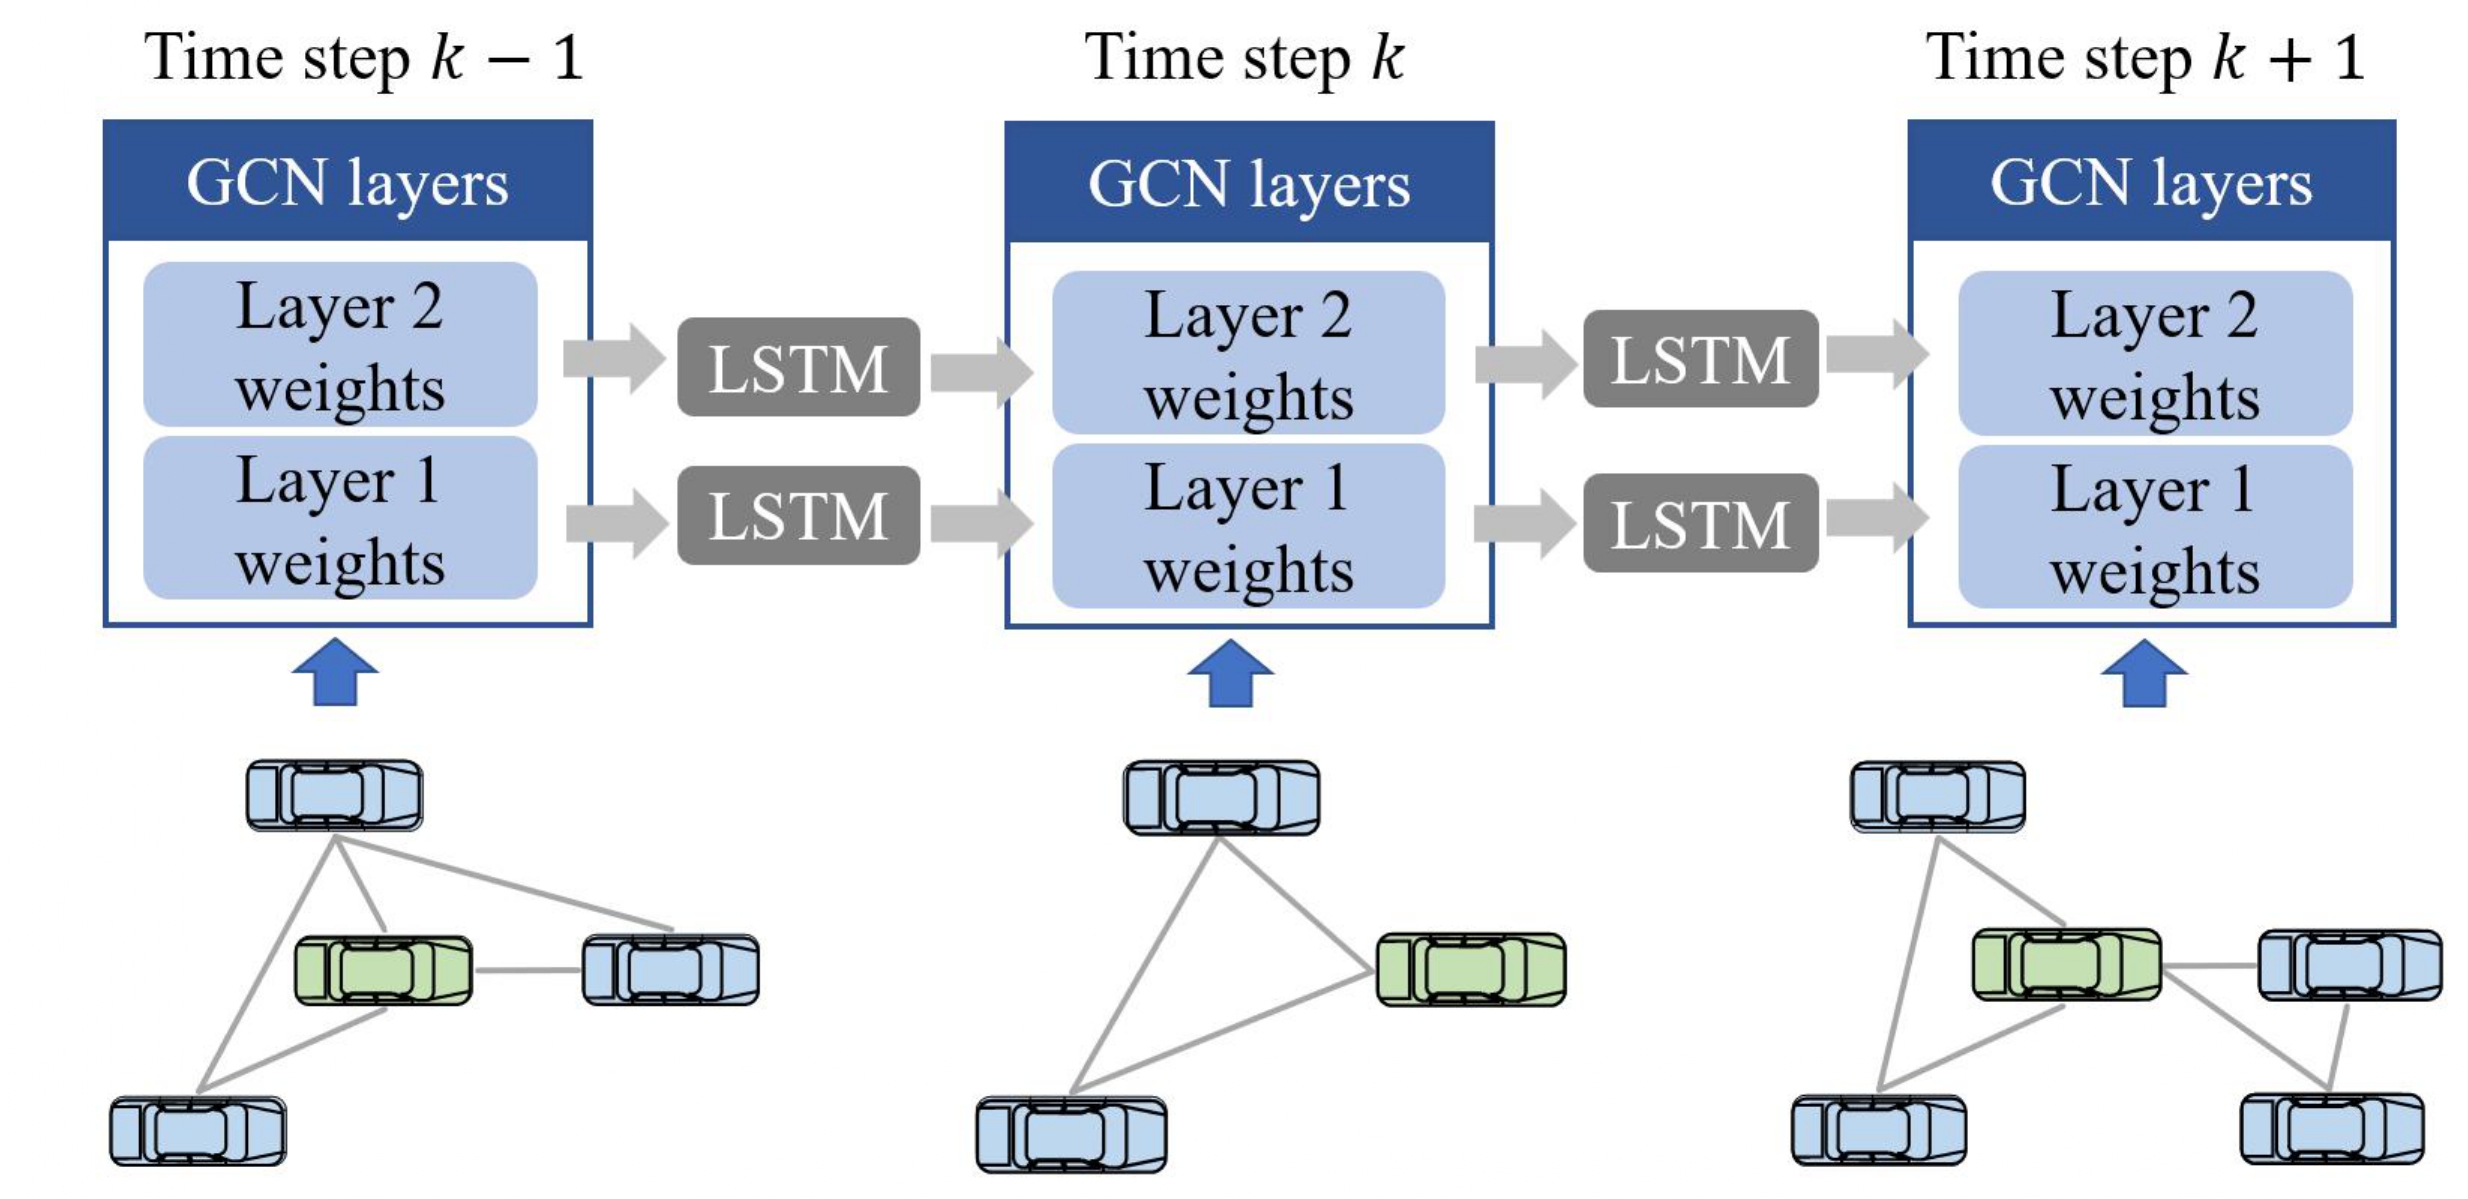
Bi-Level Control of Weaving Sections in Mixed Traffic Environments With Connected and Automated Vehicles
Longhao Yan, Jinhao Liang, Kaidi Yang
IEEE Transactions on Intelligent Transportation Systems (T-ITS), 2025
- A bi-level framework with an upper-level DRL roadside coordinator and a lower-level MPC in CAVs for global coordinated lane changes in weaving sections.
Control-Aware Trajectory Predictions for Communication-Efficient Drone Swarm Coordination in Cluttered Environments
Longhao Yan, Jinyuan Zhou, Kaidi Yang
ArXiv, 2024
- A control-aware trajectory prediction framework combining EvolveGCN and KKT-informed learning with distributed MPC for communication-efficient UAV swarm coordination in cluttered environments.

A Task-Level Emergency Experience Reuse Method for Freeway Accidents Onsite Disposal with Policy-Distilled Reinforcement Learning
Longhao Yan, Ping Wang, Fan Qi, Zhuohang Xu, Ronghui Zhang, Yu Han
Accident Analysis & Prevention (AAP), 2023
- A policy-distilled RL algorithm that transfers task-level emergency disposal experience for on-site freeway incidents.
All Publications
Journal
-
Enforcing cooperative safety for reinforcement learning-based mixed-autonomy platoon control
Jingyuan Zhou, Longhao Yan, Jinhao Liang, Kaidi Yang. IEEE Transactions on Intelligent Transportation Systems (T-ITS), 2025.
Paper -
Bi-Level Control of Weaving Sections in Mixed Traffic Environments With Connected and Automated Vehicles
Longhao Yan, Jinhao Liang, Kaidi Yang. IEEE Transactions on Intelligent Transportation Systems (T-ITS), 2025.
Paper -
Interaction-Aware Trajectory Prediction for Safe Motion Planning in Autonomous Driving: A Transformer-Transfer Learning Approach
Jinhao Liang, Chaopeng Tan, Longhao Yan, Jingyuan Zhou, Guodong Yin, Kaidi Yang. IEEE Transactions on Intelligent Transportation Systems (T-ITS), 2025.
Paper -
Enhancing System-Level Safety in Mixed-Autonomy Platoon via Safe Reinforcement Learning
Jingyuan Zhou, Longhao Yan, Kaidi Yang. IEEE Transactions on Intelligent Vehicles (T-IV), 2024.
Paper -
A Task-Level Emergency Experience Reuse Method for Freeway Accidents Onsite Disposal with Policy-Distilled Reinforcement Learning
Longhao Yan, Ping Wang, Fan Qi, Zhuohang Xu, Ronghui Zhang, Yu Han. Accident Analysis & Prevention, 2023.
Paper -
Collaborative Decision-Making Method of Emergency Response for Highway Incidents (co-first author)
Junfeng Yao, Longhao Yan, Zhuohang Xu, Ping Wang, Xinming Zhao. Sustainability, 2023.
Paper -
Refined Path Planning for Emergency Rescue Vehicles on Congested Urban Arterial Roads via Reinforcement Learning
Longhao Yan, Ping Wang, Jue Yang, Yihan Hu, Yu Han, Junfeng Yao. Journal of Advanced Transportation, 2021.
Paper
Conference / Workshop
-
Control-Aware Trajectory Prediction for Communication-Free Drone Swarm Coordination in Cluttered Environments
Longhao Yan, Jingyuan Zhou, Kaidi Yang. American Control Conference (ACC), 2025.
Paper -
Safe Reinforcement Learning for Mixed-Autonomy Platoons: A Cooperative Control Barrier Function Approach
Jingyuan Zhou, Longhao Yan, Jinhao Liang, Kaidi Yang. American Control Conference (ACC), 2025.
Paper -
RBCBF: Decoding Time Safety Alignment via Risk Guided Rollback and Barrier Control Tianxiang Chen, Jingyuan Zhou, Longhao Yan, Kaidi Yang. International Conference on Machine Learning (ICML), 2026. Paper
-
Synthesis and Verification of String Stable Control for Interconnected Systems via Neural sISS Certificate Jingyuan Zhou, Haoze Wu, Longhao Yan, Kaidi Yang. ICLR Workshop VerifAI Workshop, 2025. Paper
-
Safe-Enhanced Autonomous Driving Technology Using Conformal Prediction Results
Jinhao Liang, Ruoyu Fang, Zicheng Fang, Longhao Yan, Chaopeng Tan, Qiong Tian. Journal of Physics: Conference Series (JPCS), 2024.
Paper -
Safe Reinforcement Learning for Mixed-Autonomy Platoon Control
Jingyuan Zhou, Longhao Yan, Kaidi Yang. IEEE Intelligent Transportation Systems Conference (ITSC), 2023.
Paper -
Traffic Signal Control with Deep Q-Learning Network (DQN) at Isolated Intersection
Fan Qi, Rui He, Longhao Yan, Junfeng Yao, Ping Wang, Xinming Zhao. Chinese Control and Decision Conference (CCDC), 2022.
Paper -
An Initial Study to Use Deep Reinforcement Algorithm to Improve Efficiency of Emergency Response
Ping Wang, Longhao Yan, Jiahui Liu, Jie Wang, Ying Jin. IEEE Conference on Industrial Electronics and Applications (ICIEA), 2020.
Paper
Preprint
-
Human-Feedback-Guided Multi-Agent Inverse Reinforcement Learning for Interactive Driving Behavior Modeling
Longhao Yan, Jinhao Liang, Kaidi Yang. arXiv, 2026.
Paper -
Traffic-Context-Aware Driver Emotion Recognition with Expectation-Deviation-Driven Inference
Longhao Yan, Jinhao Liang, Kaidi Yang. arXiv, 2026.
Paper -
Control-Aware Trajectory Predictions for Communication-Efficient Drone Swarm Coordination in Cluttered Environments
Longhao Yan, Jingyuan Zhou, Kaidi Yang. arXiv, 2024.
Paper
🧾 Patent
- Image recognition method of radioactive source of cargo carried by green traffic based on convolutional neural network
CN110390341B, Granted: Dec. 2022.
📖 Education
- 2022 – Present, Ph.D., Transportation (Civil & Environmental Engineering), National University of Singapore, Singapore
- 2019 – 2022, M.Eng., Control Science and Engineering (Exempted Admission), Chang’an University, Xi’an, China
- 2015 – 2019, B.Eng., Automation (National Scientific Class for Talented Persons), Chang’an University, Xi’an, China